T-shirt folding using robotic arm
Dual robotic arm system for automated T-shirt folding with ROS 2 and computer vision
Overview
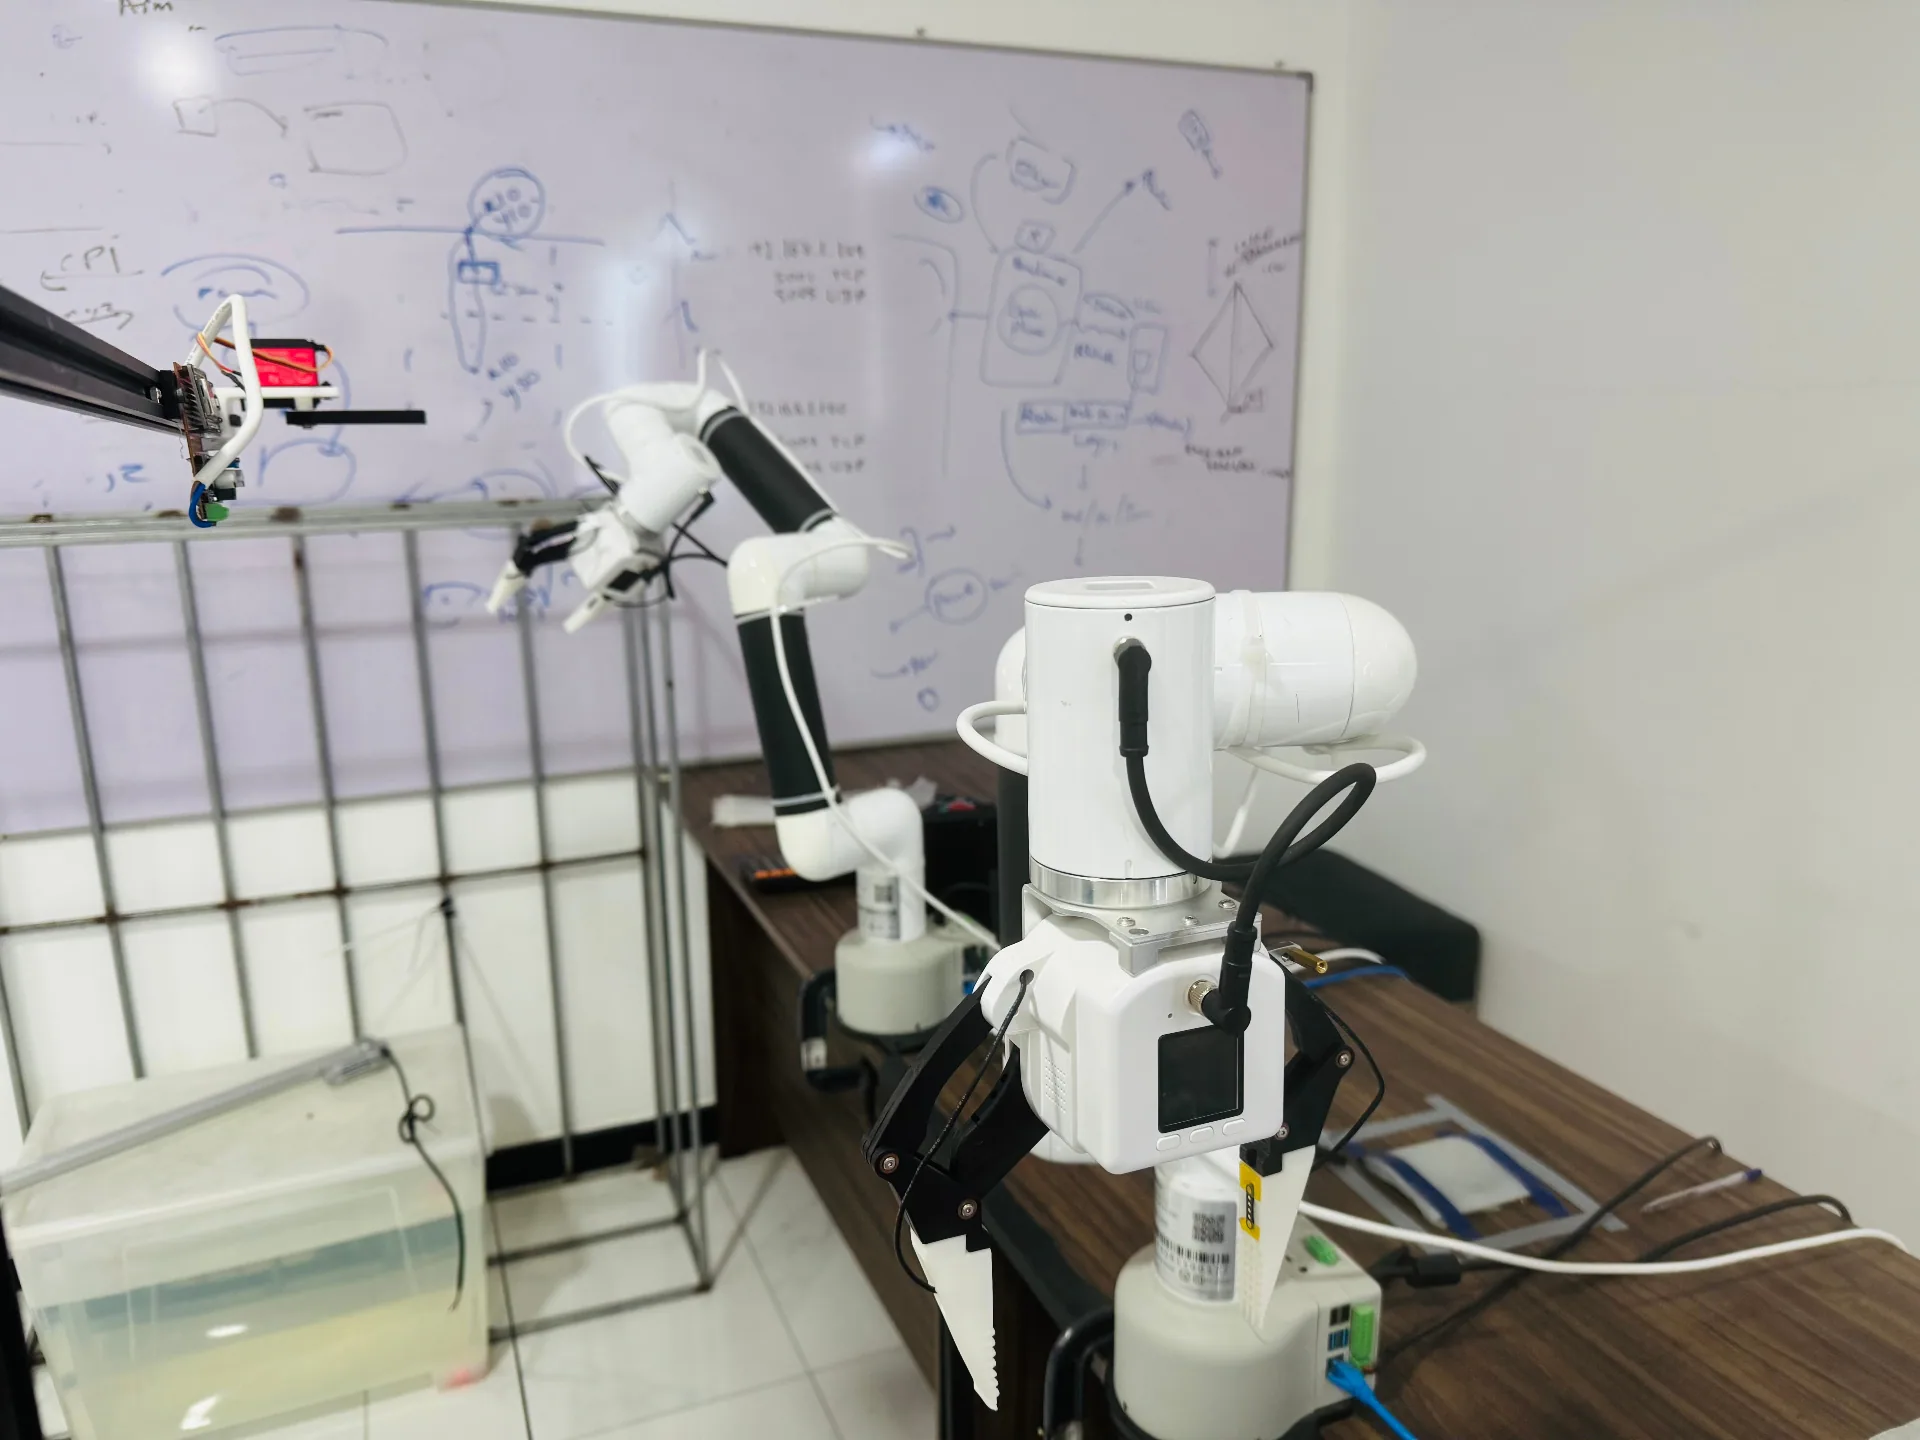
This project employs two robotic arms for T-shirt folding, aiming to pick and fold T-shirts from a pile. Controlled by ROS 2, the arms work together efficiently: one picks and positions the T-shirt, while the other folds it neatly. ZED cameras provide real-time visual data for detecting T-shirt sizes and colors, enhancing folding accuracy. Utilizing Python allows for versatility and customization to meet client needs. This innovative system boosts productivity and reduces manual labor, proving beneficial for apparel production and retail.
Key features
- Dual robotic arm coordination with synchronized motion control
- ROS 2 architecture for distributed system control and real-time communication
- ZED stereo camera for 3D perception and depth sensing
- Real-time T-shirt detection, size classification, and color recognition
- Automated pick-and-place operations with adaptive gripper control
- Intelligent folding sequence planning optimized for different garment types
- Python-based control system for easy customization and client-specific requirements
- Safety monitoring with collision detection and emergency stop capabilities
From challenge to solution
Challenge
Our solution
Coordinating two robotic arms to work in close proximity without collision
Implemented advanced trajectory planning with real-time collision avoidance algorithms
Handling fabric manipulation which is highly deformable and unpredictable
Developed specialized gripper designs with adaptive force control for gentle fabric handling
Detecting and classifying wrinkled T-shirts in various pile configurations
Created deep learning model trained on diverse T-shirt datasets for robust detection
Achieving consistent folding quality across different fabric types and sizes
Designed modular folding sequences that adapt to garment characteristics and feedback
Results & impact
- Successfully folded T-shirts with 90% quality consistency matching manual folding
- Reduced folding time by 70% compared to manual operations
- Demonstrated adaptability across 15+ different T-shirt styles and sizes
- Deployed in pilot retail operations with 95% uptime reliability
- Achieved ROI within 18 months for medium-scale retail operations
Specifications
- Arm Reach
- 850mm per arm
- Payload
- 5kg per arm
- Folding Speed
- 30-40 shirts/hour
- Detection Accuracy
- 95% size/color
- Camera Resolution
- 2.2MP stereo
- Control Frequency
- 100Hz ROS 2
Gallery
Interested in similar work?
Tell us what you are building. We’ll help you identify the clearest next step.